ESP32 38-Pin WiFi + Bluetooth NodeMCU Development Board
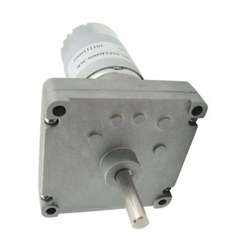
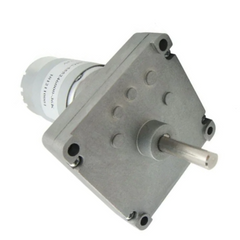
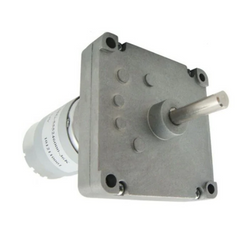
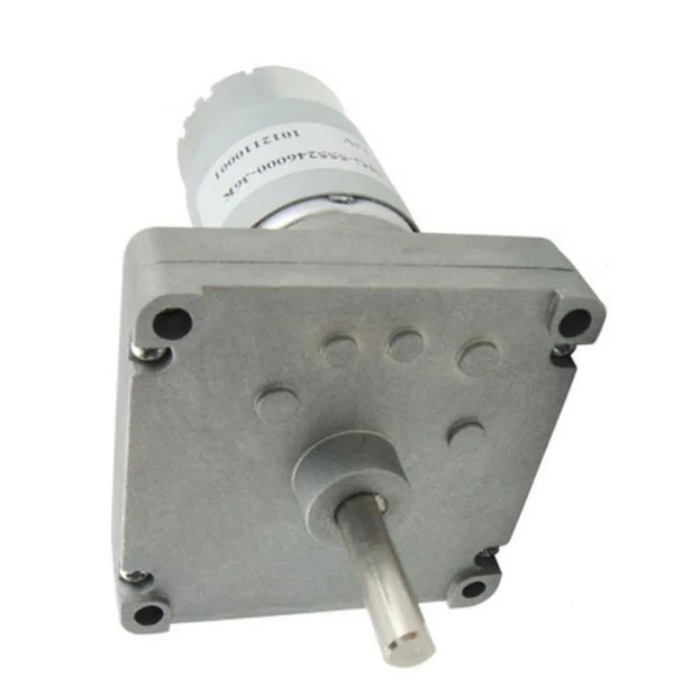
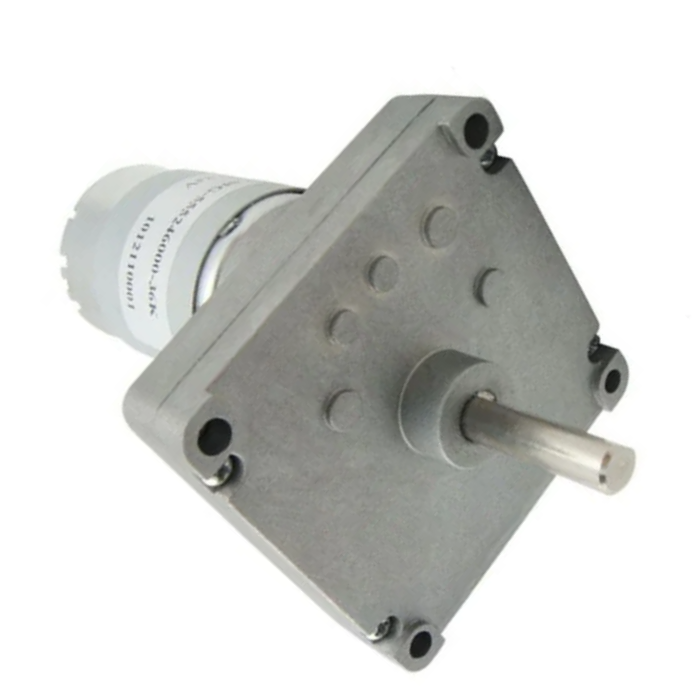
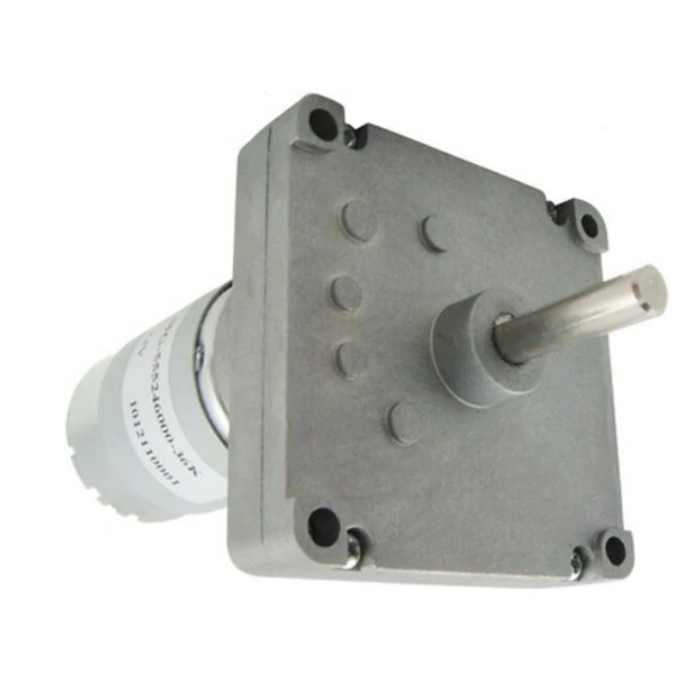
DC Rectangle Gear motor 12V 300 RPM with High Torque
Let us know!
We'll try to match the price for you
We’ll notify you once the product is back in stock.
Couldn't load pickup availability
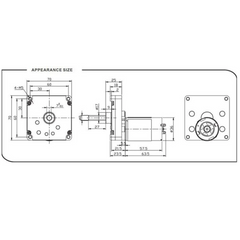
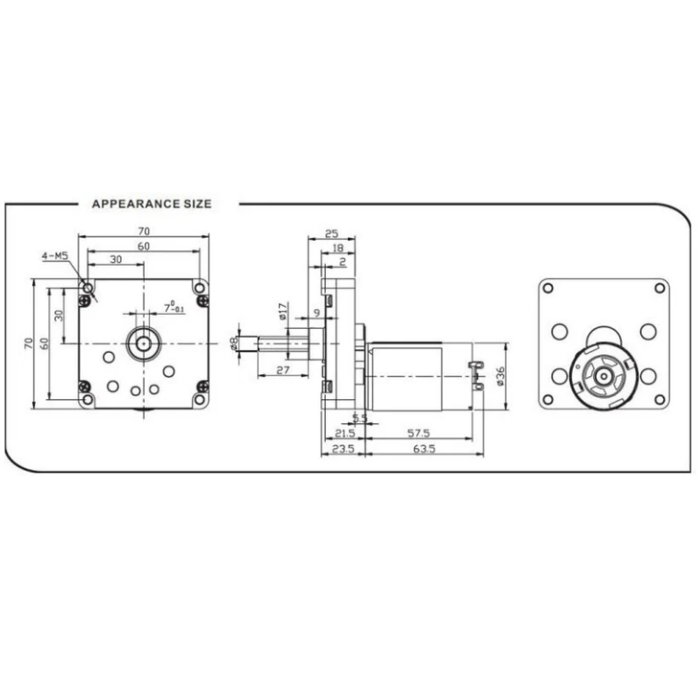
The DC Rectangle Gear Motor 12V 300 RPM with High Torque is designed for projects that need a practical balance of rotational speed, torque and dependable mechanical output. Its integrated gearbox converts the motor's rotation into a controlled 300 RPM output, making it suitable for robotics, automation mechanisms, moving platforms, conveyor systems and other DIY mechanical projects.
With a 12V operating voltage and 18 kg·cm full-load/stall torque, this gear motor is a useful choice when a standard DC motor does not provide enough mechanical force. The rectangular gearbox also gives the motor a compact, easy-to-mount form factor for custom mechanisms and equipment.
The motor draws approximately 350 mA without load, while the listed load current is 1.3 A and stall current is 6 A. A suitable motor driver should therefore be used between the controller and motor rather than connecting the motor directly to an Arduino or other microcontroller.
For robotics and automation projects, the motor can be paired with a compatible H-bridge motor driver to control direction and speed using PWM. It is suitable for makers, students, engineers and hobbyists building robot platforms, automated mechanisms, pan/tilt systems and other motion-based projects.
For more options, explore the Gear Motors and compare this 300 RPM model with other DC gear motor speeds and form factors available at Robocraze.
| Specification | Details |
|---|---|
| Rated Voltage | 12V |
| RPM | 300 (at 12V) |
| Nominal Voltage | 12V |
| No-Load Current | 350 mA |
| Load Current | 1.3 A |
| Stall Current | 6 A |
| Full (Stall) Load Torque | 18 kg·cm |
| Weight | 500 g (Approx) |
// Basic DC motor direction and speed example
// Motor is connected through an H-bridge motor driver
const int ENA = 9;
const int IN1 = 7;
const int IN2 = 8;
void setup() {
pinMode(ENA, OUTPUT);
pinMode(IN1, OUTPUT);
pinMode(IN2, OUTPUT);
}
void loop() {
// Forward
digitalWrite(IN1, HIGH);
digitalWrite(IN2, LOW);
analogWrite(ENA, 200);
delay(3000);
// Stop
analogWrite(ENA, 0);
delay(1000);
// Reverse
digitalWrite(IN1, LOW);
digitalWrite(IN2, HIGH);
analogWrite(ENA, 200);
delay(3000);
// Stop
analogWrite(ENA, 0);
delay(1000);
}
This DC gear motor provides a listed output speed of 300 RPM at 12V. The integrated gearbox reduces the motor's rotational speed while providing higher torque, making it suitable for robotics, automation and other applications where controlled mechanical movement is required.
The motor is rated for 12V DC operation. It should be used with a suitable 12V power source and an appropriate motor driver when controlled by an Arduino, Raspberry Pi, or other microcontroller.
The listed full-load/stall torque is 18 kg·cm. This makes the motor suitable for applications that need more mechanical force than a basic DC motor can provide. Actual usable torque depends on the mechanical load, operating conditions and application.
No. A microcontroller GPIO pin should not directly drive this motor. Use a suitable H-bridge motor driver and an appropriate external power supply. The motor has a listed stall current of 6 A, so the driver and power source must be selected with the motor's current requirements in mind.
This 300 RPM DC gear motor can be used in robotics, automation mechanisms, conveyor systems, pan/tilt mechanisms, DIY machines and other mechanical projects requiring a combination of speed and torque.
At 300 RPM, this motor is a relatively faster option within many geared-motor applications, while still providing substantial torque through its gearbox. It is better described as a 300 RPM high-torque DC gear motor rather than a high-speed motor intended for very high-RPM applications.